Why most bin-picking robots fail – and how AI 3D vision solves it
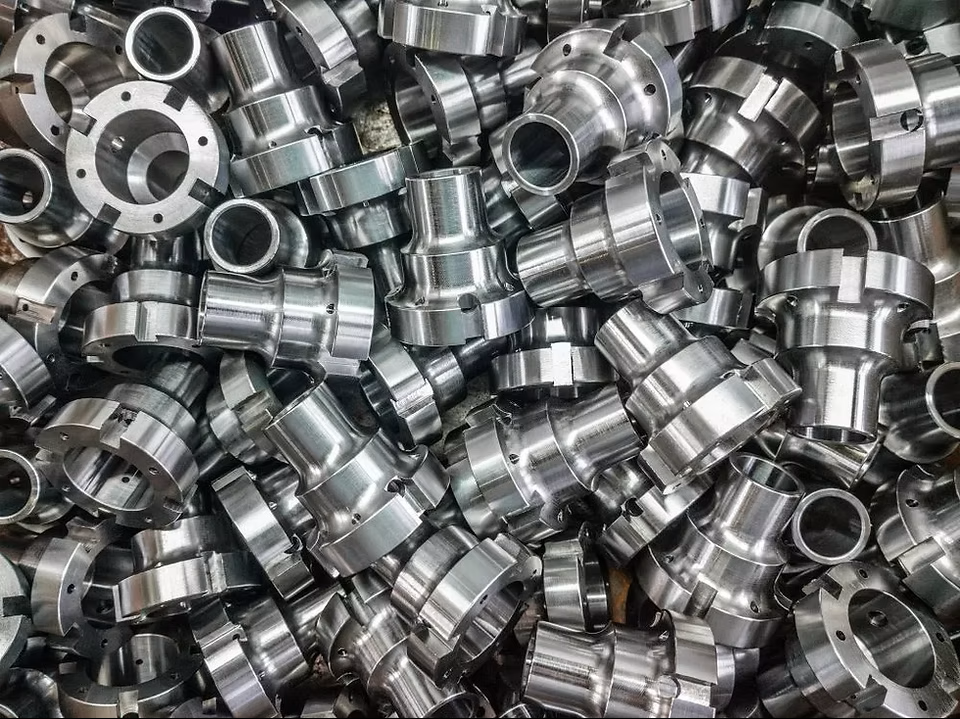
Bin picking – having a robot pick individual parts from an unordered bin – sounds simple in theory: the robot detects a part, calculates its position and picks it. In reality, many systems fail again and again in production. And the cause is rarely mechanical – it's the vision system.
Bin picking is where vision meets physics. Parts are stacked and tilted, surfaces are shiny, black, oily or transparent, and the light changes throughout the day. None of that shows up in lab conditions, but it decides whether a cell runs around the clock or stops every few hours.
Why most bin-picking systems fail
Most vision systems measure depth using light – structured light, laser triangulation or time-of-flight (ToF). They project light to calculate distance, which works in a controlled environment but struggles on a real factory floor.
- The light changes throughout the day. Structured-light systems project patterns onto parts to measure depth. When ambient light shifts – morning sun through skylights, LED reflections at midday, shadows in the evening – those patterns fade or distort. Small lighting differences make depth maps noisy and produce incorrect positions, so the robot perceives the bin differently every few hours.
- Reflective, black and transparent parts. Metal reflects the projected light unpredictably, black parts absorb most of it, and transparent parts let it pass straight through. The result: the camera sees parts twice, misses them entirely, or makes the robot pick "ghost parts". A real example: an automotive supplier's robot detected shiny bolts in the morning but failed in the afternoon once the parts became slightly oily.
- Stacking and occlusion. Real bins are never neatly organised. Parts overlap, tilt and block each other, and the camera only sees part of each object. Traditional depth sensors can't reconstruct full geometry from incomplete data, producing faulty 3D models that make the robot grab the wrong part or miss parts entirely.
- Calibration drift and vibration. Structured-light systems require precise calibration. Vibration from conveyors, temperature changes or a nudge during maintenance shift the rig by millimetres – and once the "vision" no longer matches the real bin, every pick is slightly off, until someone has to recalibrate and halt production.
- Cycle time and downtime. Fixed, light-based 3D cameras view the bin from a single angle. Stacked or hidden parts go undetected, forcing rescans or operator intervention. Many cells still need supervision nearby.
How AI + 3D vision solves it
Instead of relying on light to calculate depth, the AI-based approach is about understanding geometry – moving from "seeing light" to "understanding shape".
- Learning from CAD, not from light. A stereo camera captures spatial data from two synchronised viewpoints. An AI model trained on the CAD data of the target parts already knows what each part should look like in 3D – its edges, curves, holes and surfaces. When the robot looks into the bin, what it sees is matched against those learned shapes, even when parts are partially covered, rotated or overlapping. This is called geometry-based perception.
- Independent of light. Because the system learns shapes rather than shades, lighting becomes irrelevant. It works equally well near windows, under fluorescent lights or beside a welding line – with no projected light, infrared or calibration cages. That's why it works just as well across cosmetics, automotive and electronics, where reflection, transparency and variable light are common.
- Precision through real 3D understanding. Where conventional 3D cameras calculate a single depth value per pixel, the AI builds a dense geometric representation of each part, understanding where objects begin and end and how they're oriented. This lets the robot calculate stable 6D poses (position and rotation) in real time, typically within about 200 milliseconds – giving shorter cycles and fewer re-grasps.
Traditional vs AI-based 3D vision
| Problem | Traditional 3D vision | AI-based 3D vision |
|---|---|---|
| Lighting variation | Unstable, frequent recalibration | Works under all lighting |
| Reflective/transparent parts | Missing data, noise | Clear geometry and poses |
| Stacked parts | Pose confusion | AI separates individual parts |
| Calibration drift | Regular re-alignment required | Mechanically stable rig |
| Cycle time | 6–10 s typical | 2–8 s typical (≈200 ms prediction) |
At a factory in South Korea, switching to AI-based vision reduced false detections by 90% and cut average cycle time by 40% – enabling true 24/7 production without manual resets.
Beyond bin picking
Accurate geometric perception opens up more than picking:
- Sorting of mixed or randomly placed parts.
- Cable and wire handling for flexible components.
- Kitting and assembly in more advanced automation.
A system first deployed for bin picking was later reused to place transparent bottles on a packaging line – with no new lighting, calibration or hardware, simply by retraining the AI.
What it means for you
Bin picking is still one of the hardest perception tasks in automation. By learning geometry instead of relying on light, picking becomes stable, fast and accurate – regardless of light, material or industry. As a Cambrian Robotics partner, we at SE Automation help you assess whether your picking application is production-ready. Contact us and we'll look at your process together.
Source: Cambrian Robotics.